07 · Mechanical · Team project
DRS Linkage and Torque Solver
The linkage and actuator sizing for the drag reduction system (DRS) on Penn Electric Racing's car, and DRSSim, the torque solver I wrote to size it.
The problem
A drag reduction system rotates the rear wing's elements to shed drag on the straights, and puts them back for downforce in the corners. Two linked airfoils make that a coupled mechanism: a force on one is carried to the other through a coupler, so the actuator has to be sized for the whole linkage, not for one element.
What I built
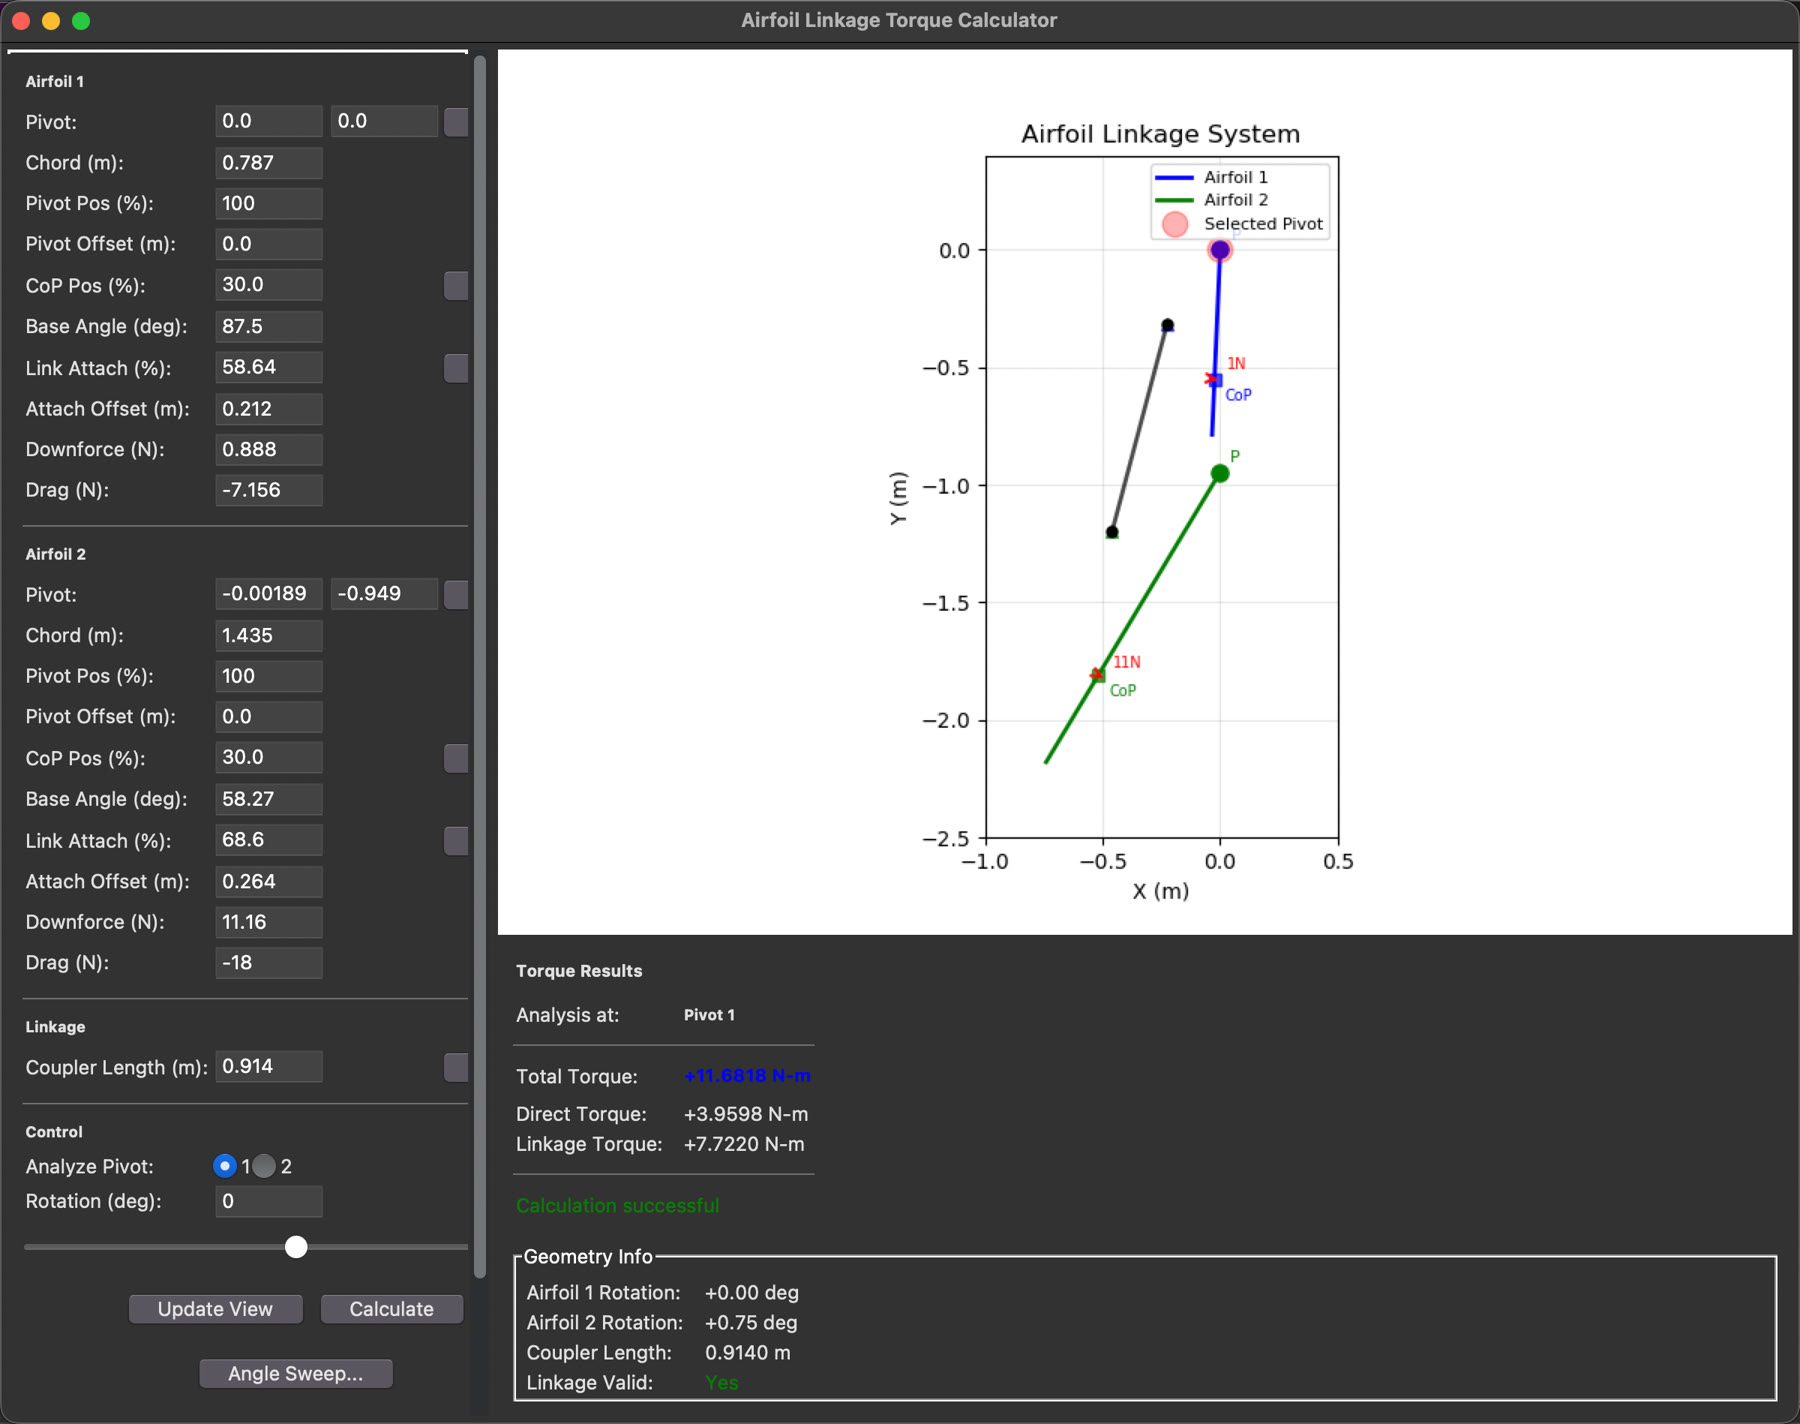
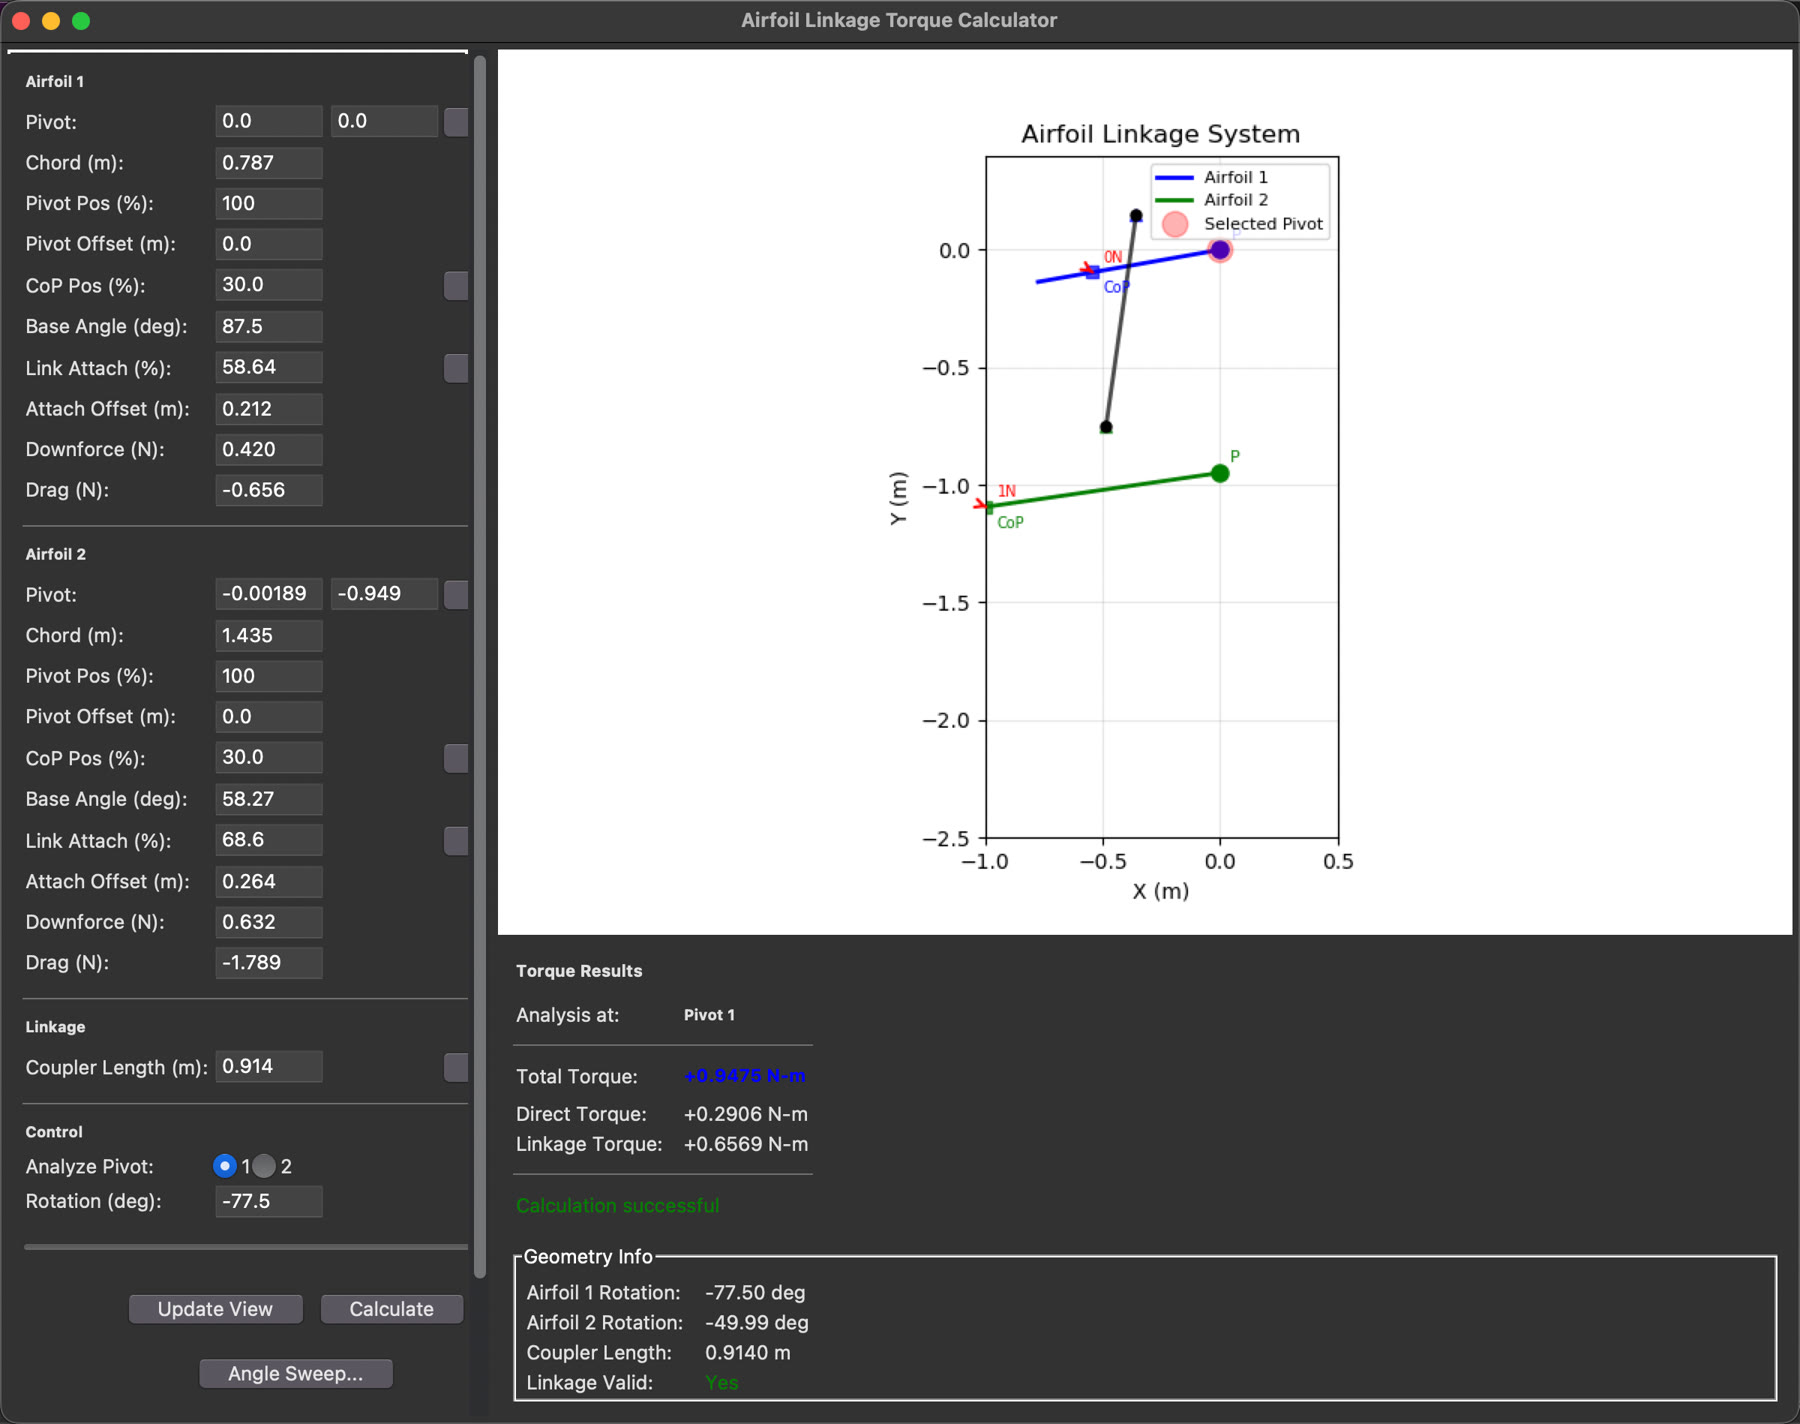
As a mechanical team member I designed the linkage for the car's DRS and sized its actuator using force analysis. To do that I wrote DRSSim, a desktop tool that models the two airfoils and the coupler and reports the torque at each pivot.
For each airfoil you enter the pivot, chord, pivot and centre-of-pressure positions, base angle, link attachment point and offset, and the downforce and drag acting on it, plus the coupler length. It separates direct torque (aerodynamic load on that airfoil at its centre of pressure) from linkage torque (load carried through the coupler from the other airfoil). Their sum is the net torque the actuator has to overcome. An angle sweep runs it across the whole travel, and a servo mode takes crank length, offset and rod length and returns the linear actuator force and its moment arm.
- 11.68 N·m
- net torque, DRS off (screenshot values)
- 0.95 N·m
- net torque, DRS on at −77.5°
- 23
- assertions in 6 test functions
- 2.6K
- lines of Python
How it is checked
The repository has a test suite covering vector operations, airfoil geometry, direct torque, linkage kinematics, torque transmission through the coupler, and a full-system case, plus a separate verification script that prints every intermediate value for a fixed configuration so the hand calculation can be compared line by line. Along the way I fixed the linkage solver to account for perpendicular offsets and to normalize angles correctly.
If this is the kind of work you need, let's talk.
Coffee chat